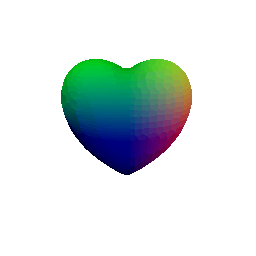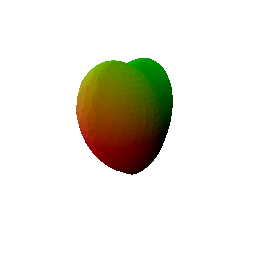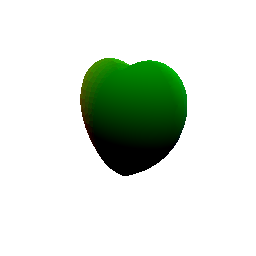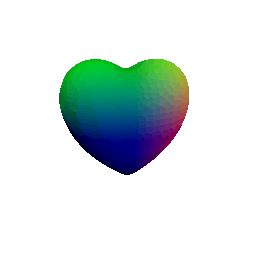Jerry Hou (jerryhou)


The tetrahedron mesh has 4 vertices and 4 triangular faces.
The cube mesh has 8 vertices and 12 triangular faces (2 triangles per cube side).
color1 = [0, 1, 0.3] and
color2 = [1, 0, 1]

Rotate the camera 90° counterclockwise about the z-axis so the cow appears rotated in the image plane. No extra translation.

R_relative=[[0, 1 , 0],
           [-1, 0, 0],
           [0, 0, 1]],
T_relative=[0, 0, 0]
Keep the same orientation and push the camera farther along z so the cow looks smaller.

R_relative=[[1, 0 , 0],
            [0, 1, 0],
            [0, 0, 1]],
T_relative=[0, 0, 3]
A small relative rotation plus a short move along −z, which shifts the viewpoint slightly and brings the cow closer.

cos = np.cos(np.radians(5))
sin = np.sin(np.radians(5))
R_relative=[[cos, 0 , sin],
            [0, cos, -sin],
            [-sin, sin, cos*cos]],
T_relative=[0, 0, -0.5]
Rotate 90° about the y-axis and translate by [-3, 0, 3]
so the camera looks at the cow from the side while staying the same
distance from the origin.

cos = np.cos(np.radians(90))
sin = np.sin(np.radians(90))
R_relative=[[cos, 0 , sin],
            [0, 1, 0],
            [-sin, 0, cos]],
T_relative=[-3, 0, 3]pointcloud1 -> pointcloud2 -> union of pointcloud 1 and 2 in order:


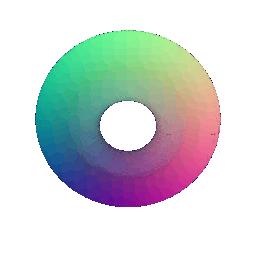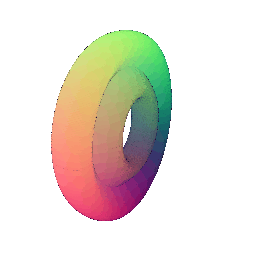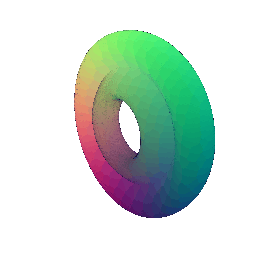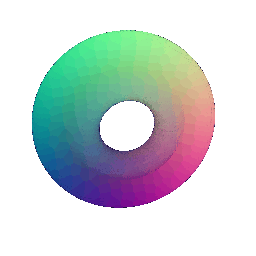
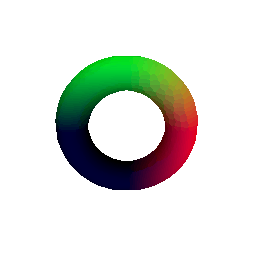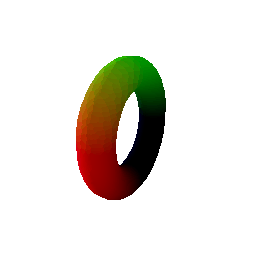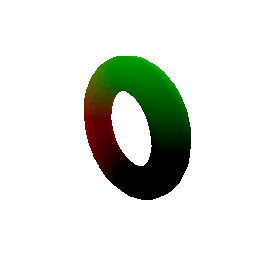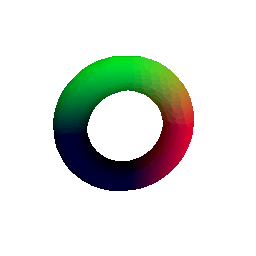
Rendering quality: Meshes usually provide better visual quality because they have continuous surfaces and support detailed textures. Point clouds can look sparse or coarse unless they contain a lot of points.
Rendering speed: Sparse point clouds can be fast to render because there is no need to rasterize triangles. However, very dense point clouds can become expensive to render.
Ease of use: Point clouds are simpler because no surface connectivity is required. Meshes require defining vertices and faces, which can take additional processing.
Memory usage: Point clouds only need to store points and optional attributes such as color, but representing a detailed surface may require a very large number of points. Meshes need additional face information, but they can often represent smooth surfaces using fewer vertices.
Texture and appearance: Meshes make it much easier to apply detailed textures and realistic materials, like through an image. Point clouds usually rely on per-point colors, so fine texture details are harder to represent.