


3. Re-texturing a mesh

colors chosen:
color1 = [0, 1, 1]
color2 = [1, 1, 0]
4. Camera Transformations

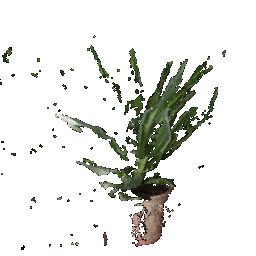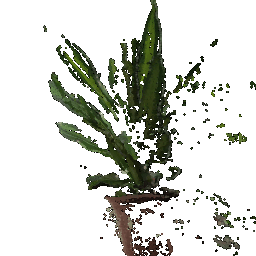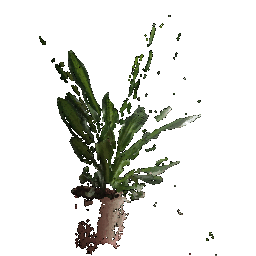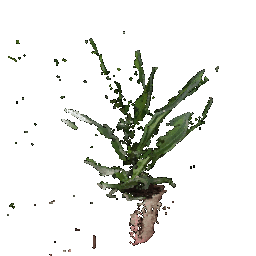
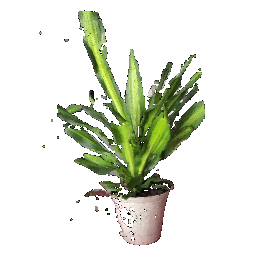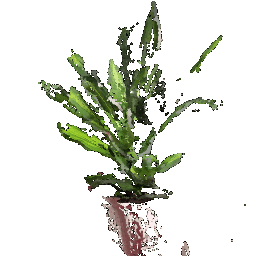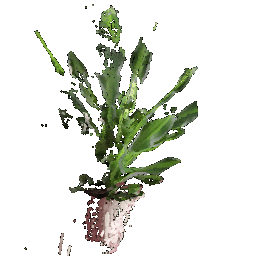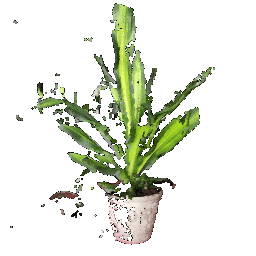
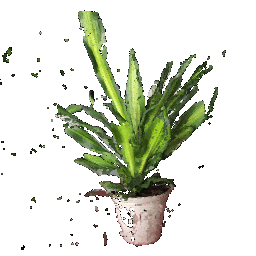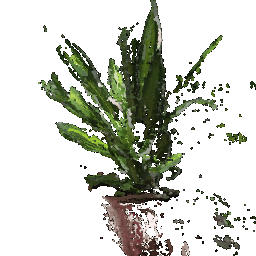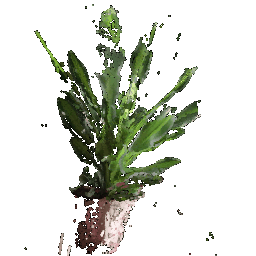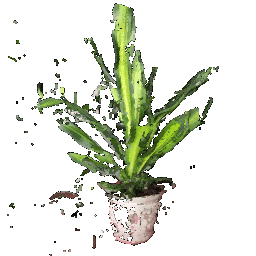
The camera is rotated -90 degrees along +z axis
$ T_{relative} = \begin{bmatrix}
0 & 0 & 0 \\
\end{bmatrix}
$
$ R_{relative} = \begin{bmatrix} 0 & 1 & 0 \\ -1 & 0 & 0 \\ 0 & 0 & 1 \end{bmatrix} $

The camera is translated by 2 units in -z
$ T_{relative} = \begin{bmatrix}
0 & 0 & 2 \\
\end{bmatrix}
$
$ R_{relative} = \begin{bmatrix} 1 & 0 & 0 \\ 0 & 1 & 0 \\ 0 & 0 & 1 \end{bmatrix} $

The camera is translated by 0.5 units in -x
$ T_{relative} = \begin{bmatrix}
0.5 & 0 & 0 \\
\end{bmatrix}
$
$ R_{relative} = \begin{bmatrix} 1 & 0 & 0 \\ 0 & 1 & 0 \\ 0 & 0 & 1 \end{bmatrix} $

The camera is rotated 90 degrees along +y axis
Then it is translated by 3 units in -x
Then it is translated by 3 units in +z
$ T_{relative} = \begin{bmatrix}
-3 & 0 & 3 \\
\end{bmatrix}
$
$ R_{relative} = \begin{bmatrix} 0 & 0 & 1 \\ 0 & 1 & 0 \\ -1 & 0 & 0 \end{bmatrix} $
5.2 Parametric Functions
Parameteric Function of a Torus

Parameteric Function of a Trefoil

5.3 Implict Function
Torus

The tradeoff of rendering a mesh vs point cloud comes down to maintaining connectivity and smoothness. Implicit functions depend on the voxel size. They are often coarse and finer voxel sizes take a long time to render. But they maintain connectivity.
Where as point clouds are faster to render and give a smoother surface, but they don't have any connectivityanother random obj
