bojiang
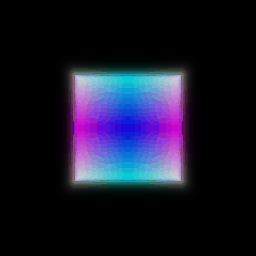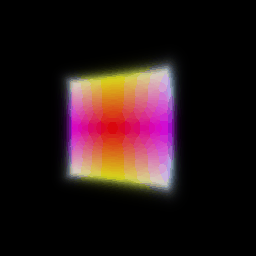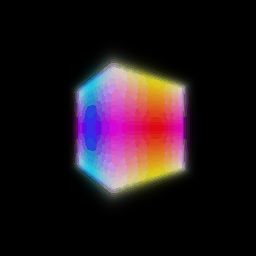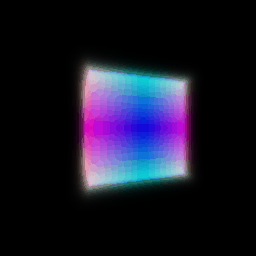
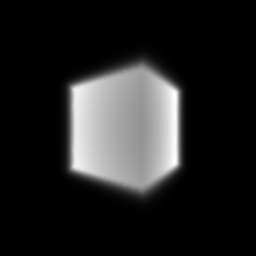
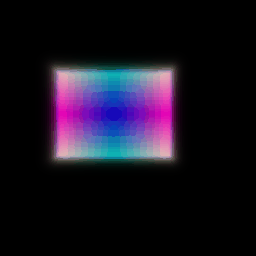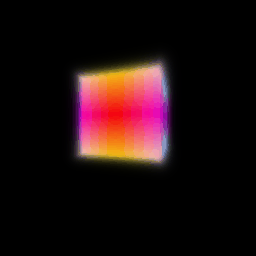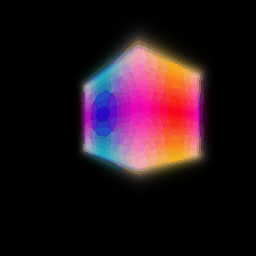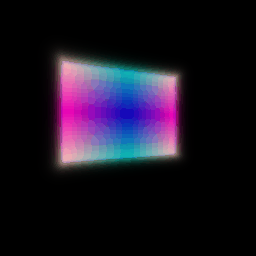
After 1,000 epochs, the box center is (0.25, 0.25, 0.00) and its side lengths are (2.01, 1.50, 1.50), rounded to 0.01. The optimized silhouette, position, and rainbow appearance closely match the provided reference.
The position-only Lego NeRF was trained for 250 epochs at 128×128 resolution. Across 200 test views: PSNR 24.32 dB, SSIM 0.8871. The main shape is reconstructed, while fine details remain soft.
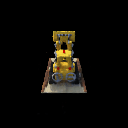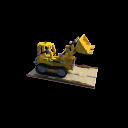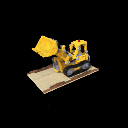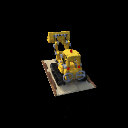
Color depends on position and viewing direction; density depends only on position. A small color head with two direction-encoding frequencies limits angular capacity. View dependence can represent reflections, but greater angular capacity can memorize training cameras and generalize poorly between views. Fewer direction frequencies or angular regularization can improve generalization while smoothing sharp highlights. This Materials reconstruction retains blurred reflections.

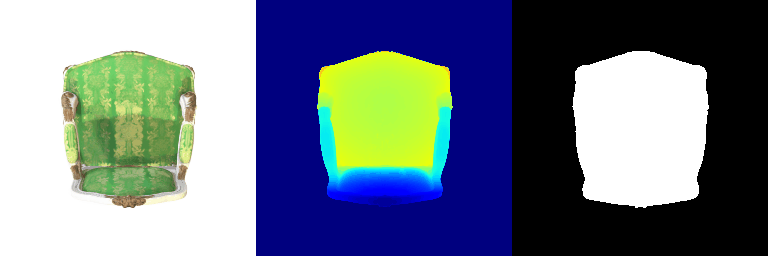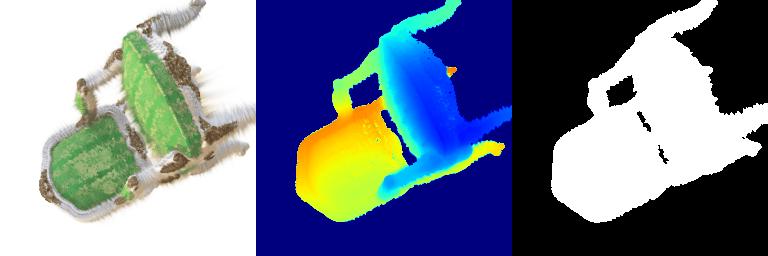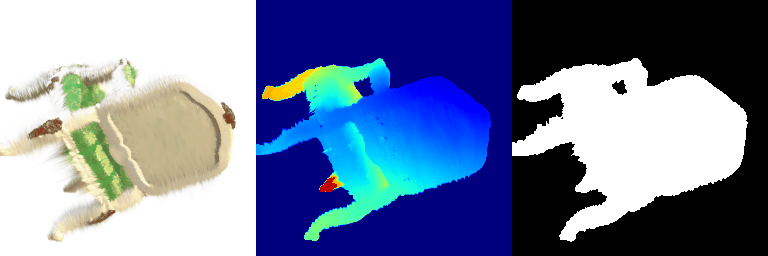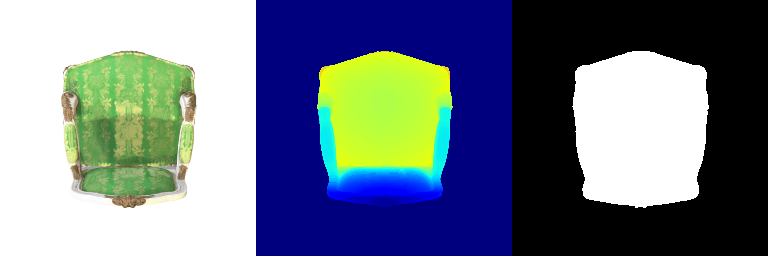
Trained 10,000 isotropic Gaussians for 1,000 iterations with Adam and L1 RGB loss. Across all five held-out views: PSNR 29.19 dB; SSIM 0.9366.
| Parameter | Learning rate |
|---|---|
| Means | 0.0001 |
| Log-scales | 0.005 |
| Opacity logits | 0.05 |
| Colors | 0.01 |
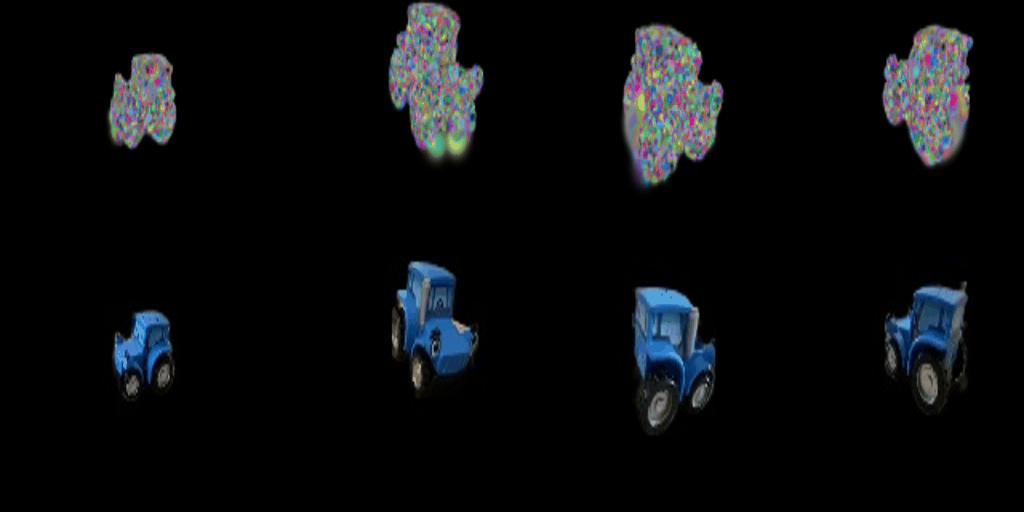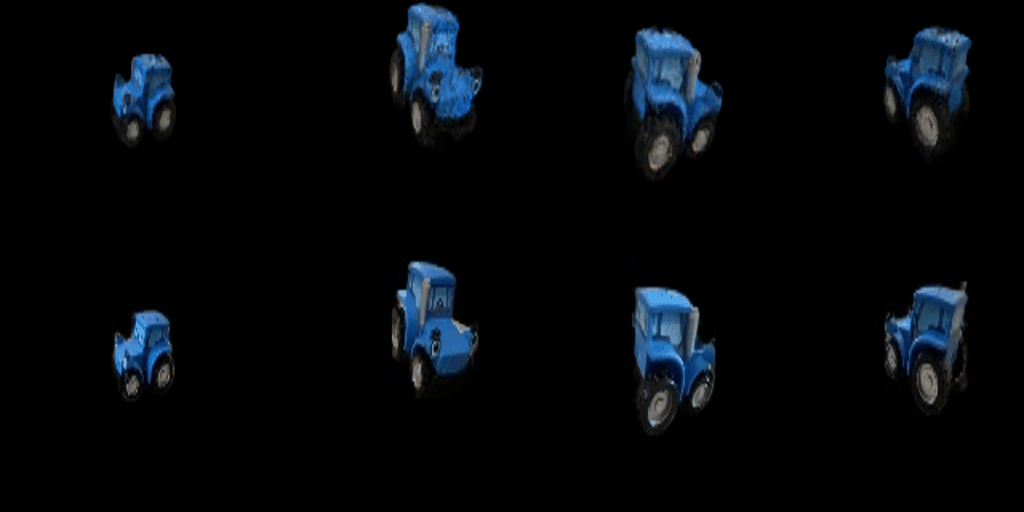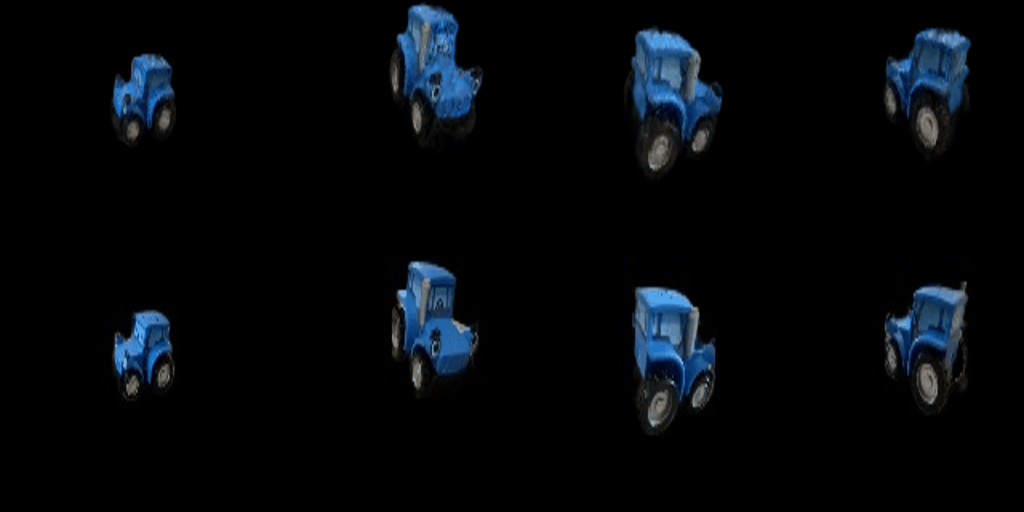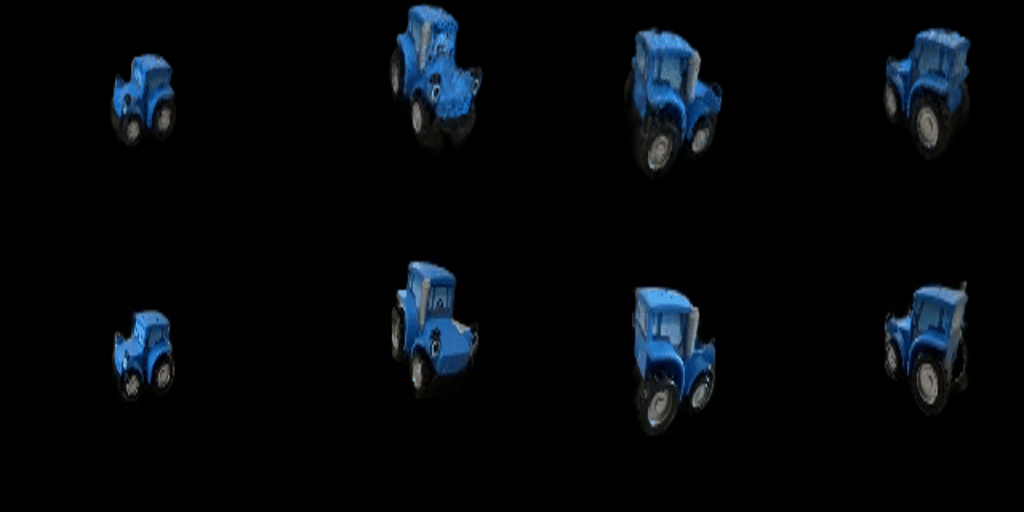

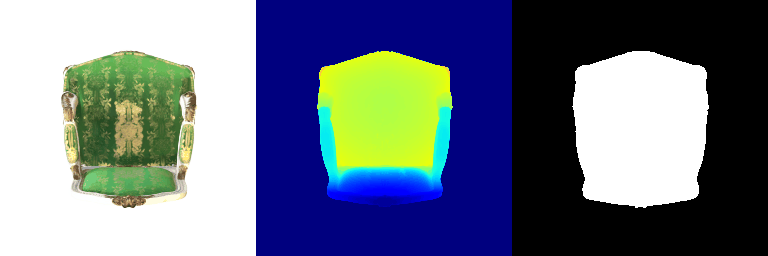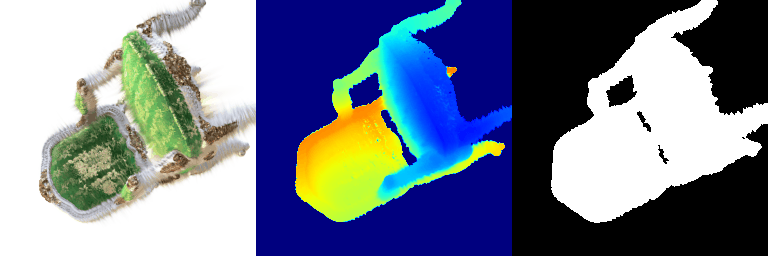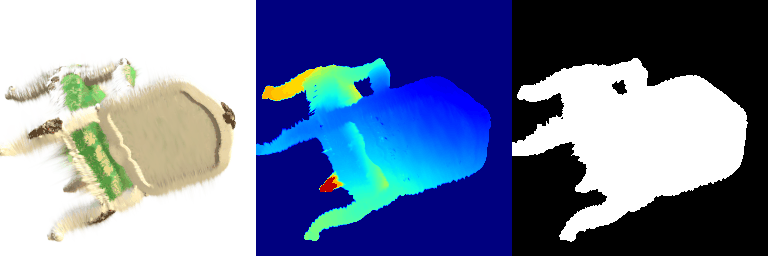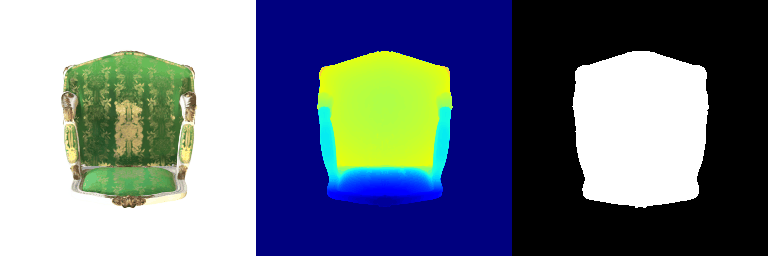
The pretrained chair is rendered with degree-3 spherical-harmonic color. The DC-only GIF is shown in Section 5; the full-SH GIF is below. Geometry and cameras are identical in both modes.